
A physical environment for embodied welding AI
Jointly developed by JITRI and Nanjing Jiangbei New Area, the robotic welding training ground brings welding equipment, data collection and model development into a shared physical environment. It is a place for robots to acquire high-quality industrial data and for AI models to improve through real welding tasks.
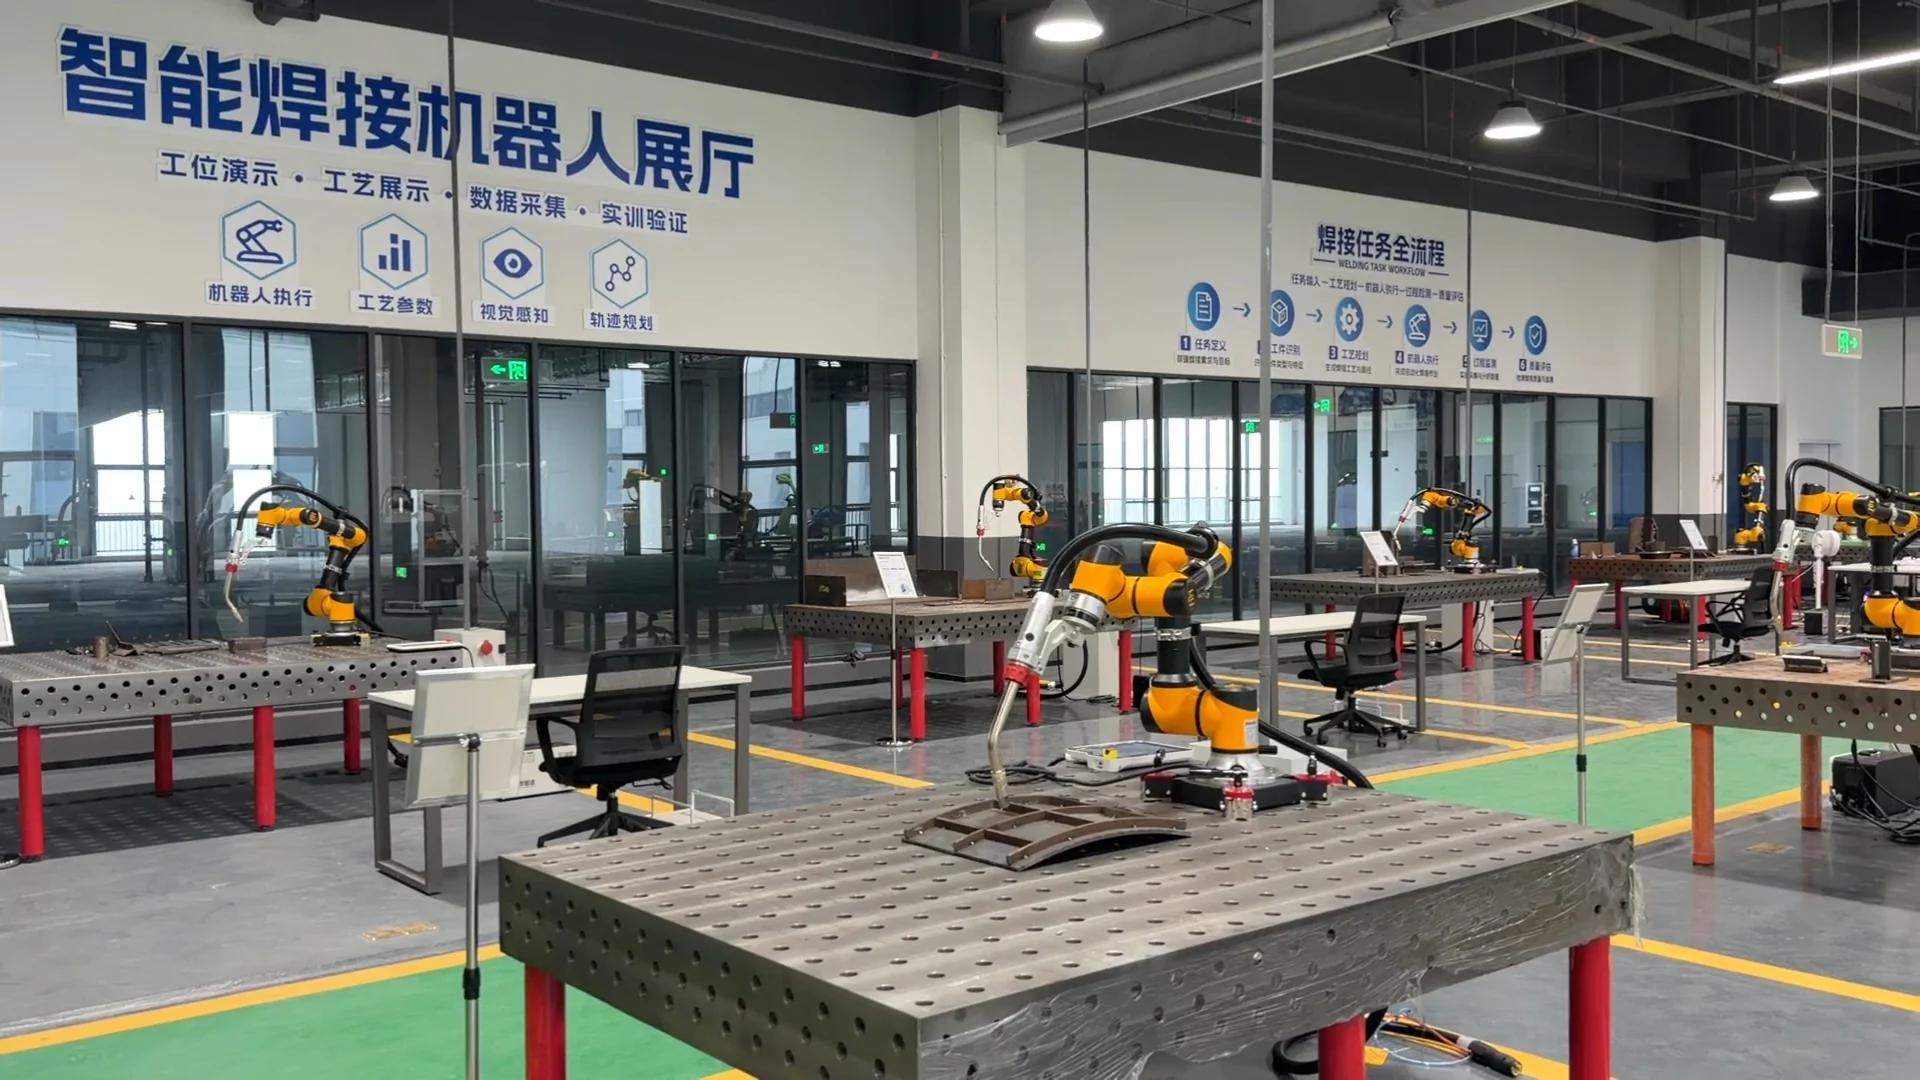
Collecting data throughout the welding process
The training ground combines multimodal sensors, vision cameras and industrial welding power sources. It captures visual feedback, force sensing, temperature readings and arc characteristics during welding, providing data for physical AI and world-model development.
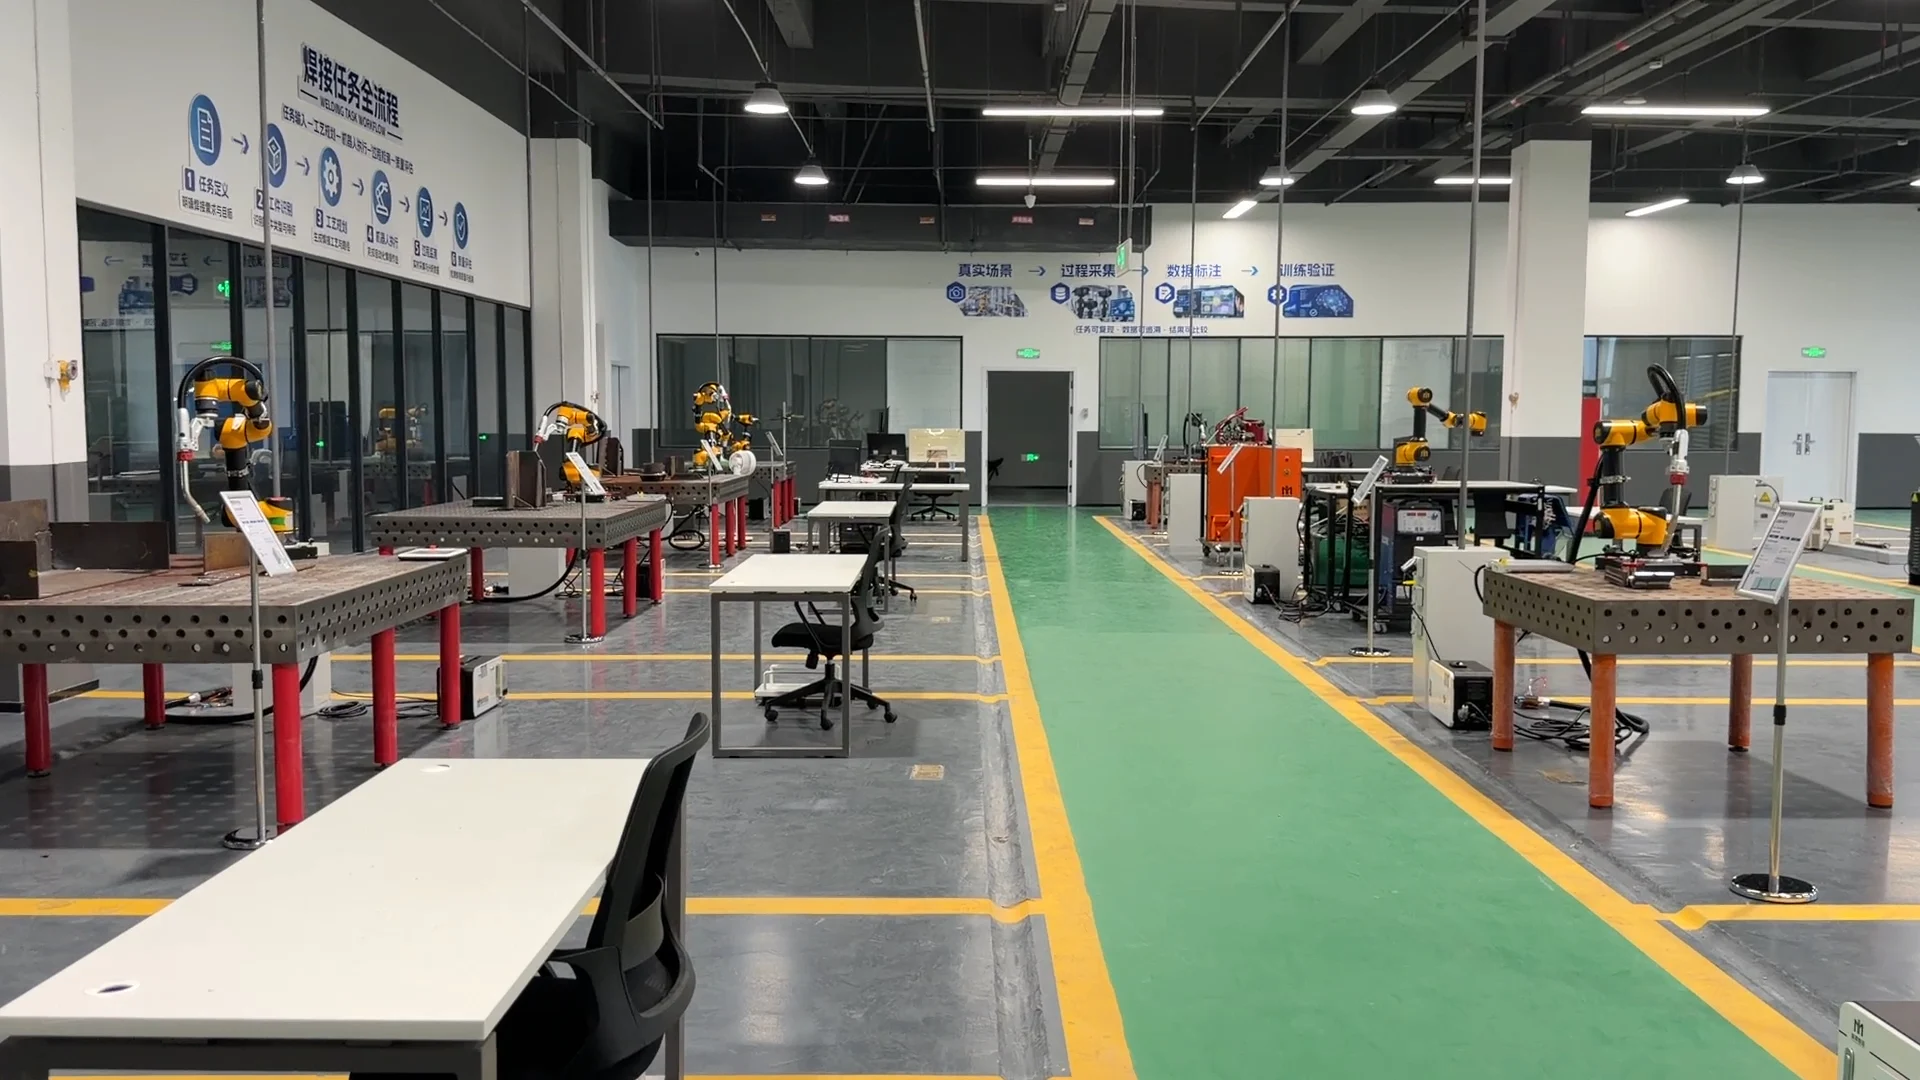
From data to model iteration
Data collected in the physical environment feeds a continuous loop of model training, execution and feedback. The goal is to help robots develop autonomous perception, path planning and adaptive capabilities, moving beyond rigid pre-programmed teaching commands.
Complex trajectories, curved seams and workpiece deviations remain important challenges in robotic welding. The training ground supports data-driven exploration of these non-standard conditions and the development of more adaptable robotic welding systems.
A shared environment for application validation
The facility connects data collection, robot execution and feedback in one environment. This allows physical AI development to remain grounded in welding tasks and the conditions encountered on factory floors.
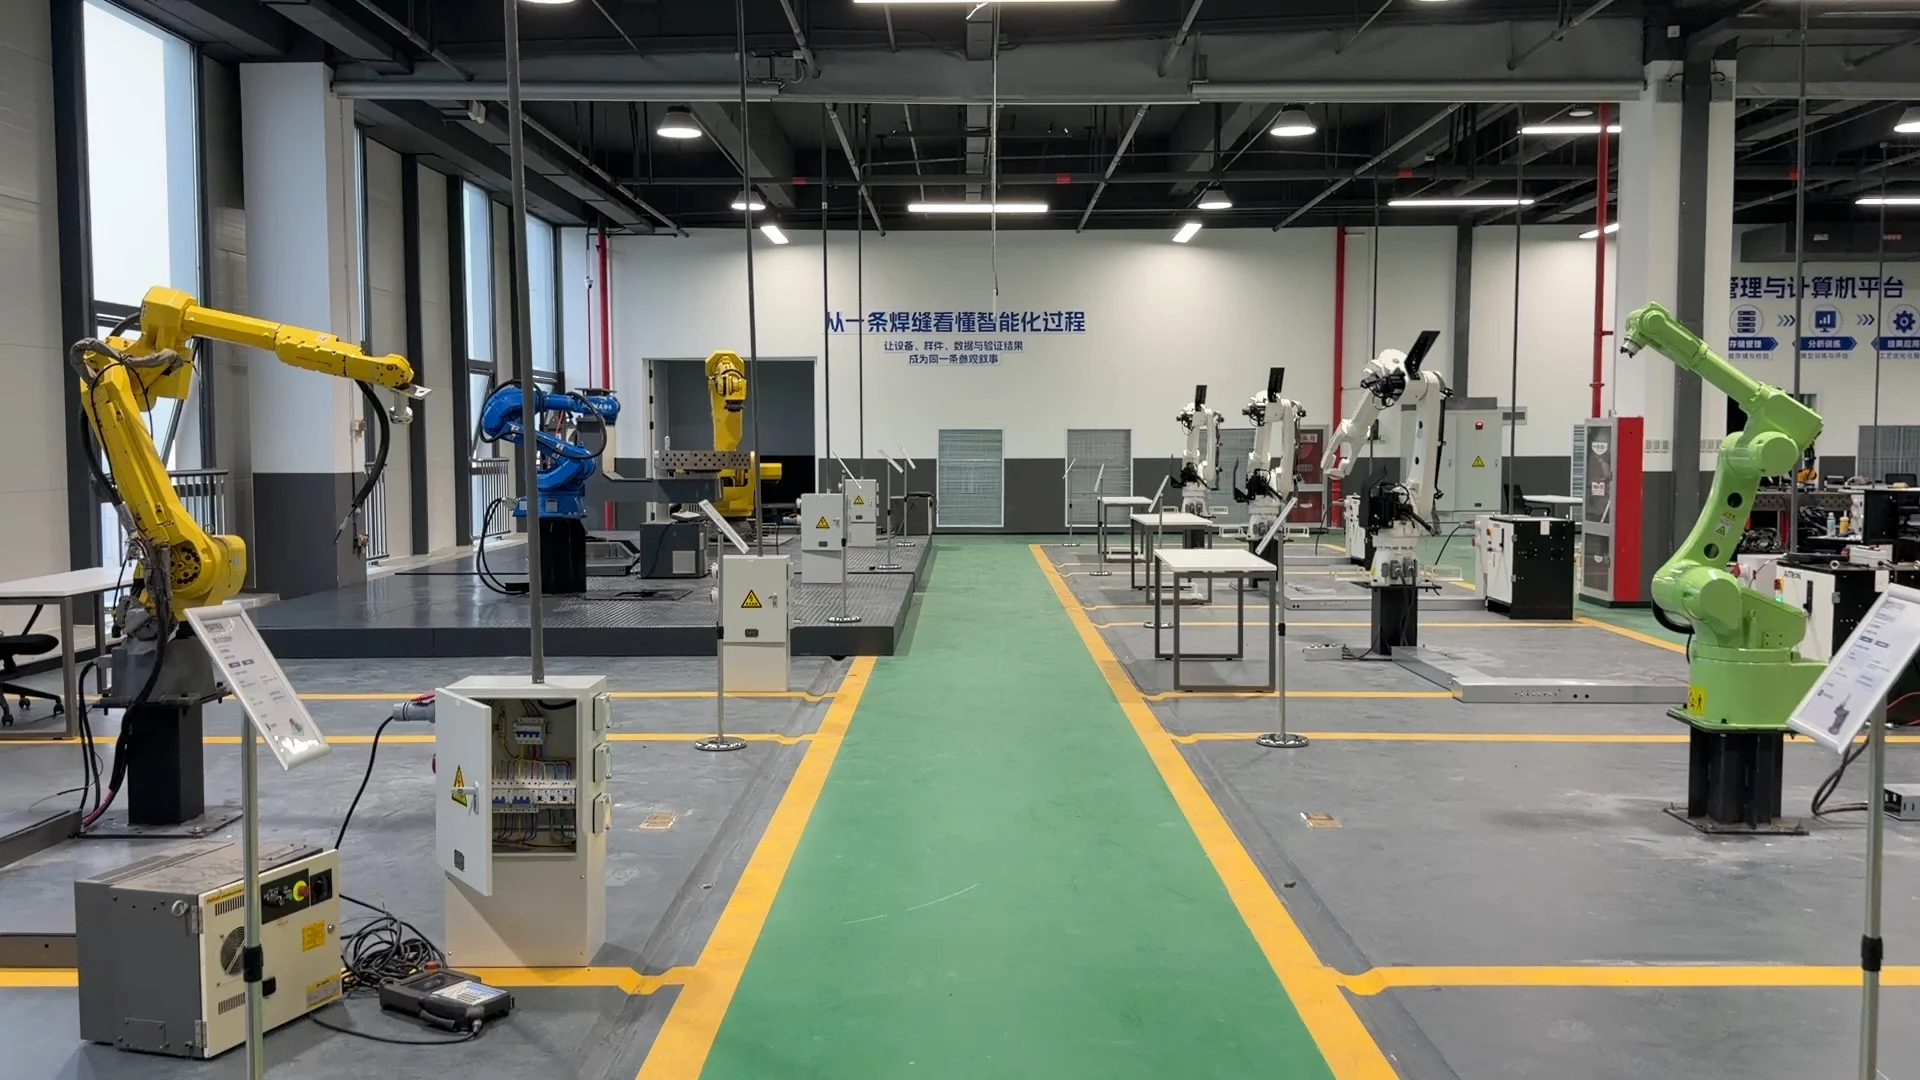
A foundation for high-quality industrial datasets
JITRI’s “High-Quality Dataset Development for Embodied Intelligent Welding Robots” project was selected for the 2026 Jiangsu Provincial Key High-Quality Dataset Construction Project List. The training ground and the dataset project support the transition of AI from digital simulation into physical industrial applications.
Together, they provide infrastructure for data-driven robotics and the long-term development of intelligent welding. The original company announcement remains available in News for the full project background.